Know why your robot failed.
Naiva records every layer of your robot, from operator input to motor current, on one timeline. When something goes wrong, it shows where it started and keeps signed evidence.
Free in simulation · Active monitoring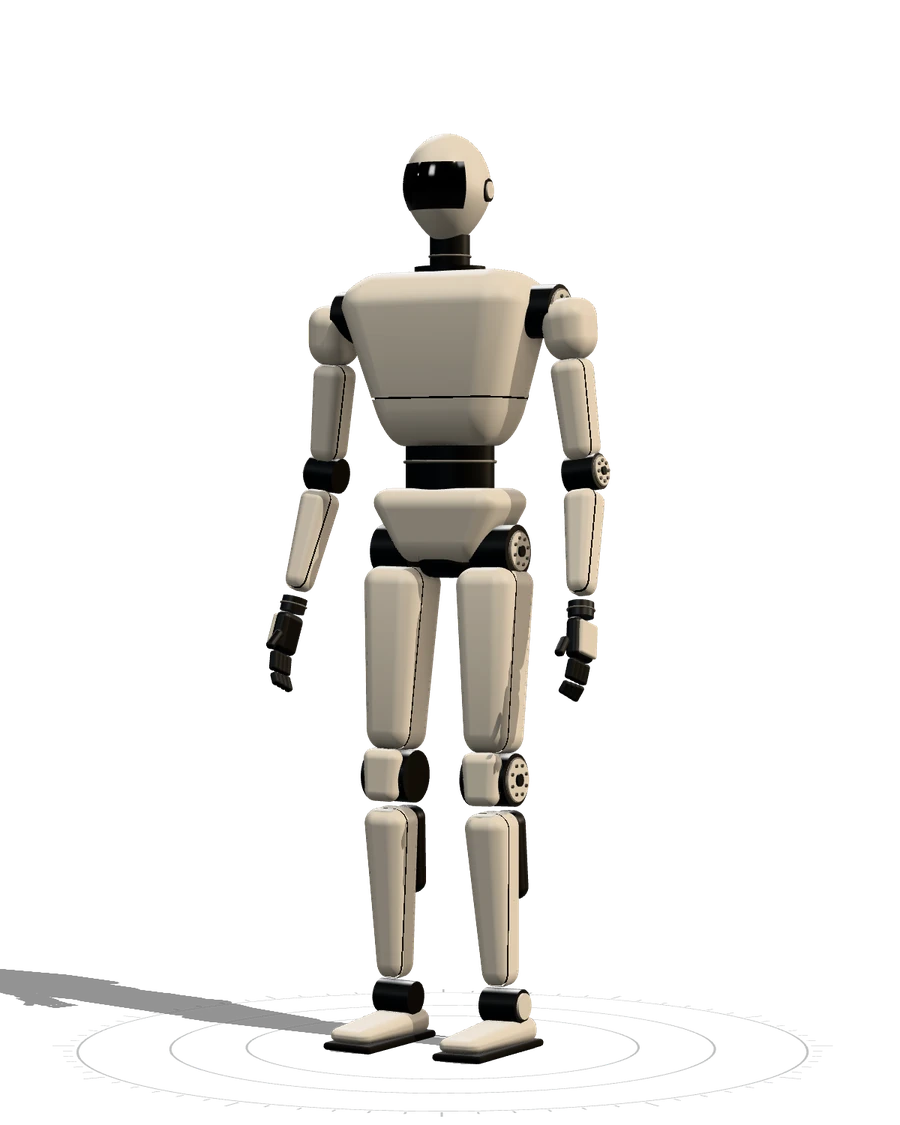 Left knee · changed first
Left hip · steady
Left shoulder · steady
Right elbow · steady
Your robot failed. Now what?
Small robotics teams hit four problems, usually at once.
Which layer broke?
Operator input, AI model, planner, timing, joints, motors, sensors. Seven logs, searched one at a time.
Wear you never saw
Gearboxes, motors and brakes degrade for weeks inside data you already collect.
Questions you can't answer yet
Pilot customers and assessors ask for evidence of what worked and what did not.
Upcoming regulatory deadlines
The EU Machinery Regulation applies from 20 January 2027. Are your deployments affected?
One timeline across every layer.
Naiva lines up operator input, the AI model, the planner, timing, motors and sensors. When something fails, it shows where and which layer changed first.
From install to first report in three steps.
Watch-only until you decide.
Naiva is never in the command path. Protection with LCM-1 is a separate step you can choose to turn on later.
Read how evidence is recordedNever sends commands
Naiva reads your robot's signals. Nothing it does can move the robot.
Your models stay yours
We never retrain your AI models. Naiva watches behaviour, not model internals.
Cameras and prompts stay with you
Shared only if you choose to share them.
Records you can prove
Signed to show they are unaltered. Recording continues offline.
Visibility first. Protection last.
Run Naiva free in simulation.
Join the waitlist for the simulation download. Places open in small groups.
Join the waitlistPut Naiva on your real robot.
Early access and direct contact with our engineers. We ask for your feedback on each release.
Apply as a design partner